Physicl Secures $10M Seed to Solve the Robotics Data Bottleneck with 3D Simulation
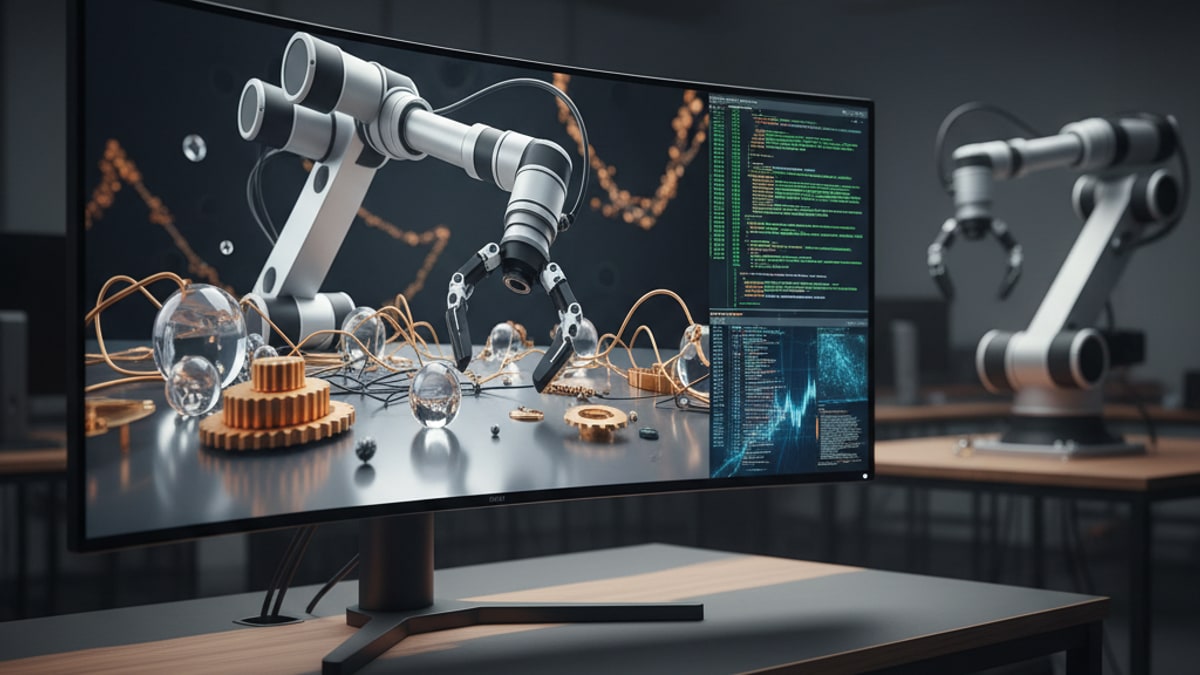
As the physical AI sector struggles to find enough high-quality training data, Physicl has raised $10 million to generate realistic 3D edge cases for robots.
The biggest bottleneck in physical AI is no longer compute power or algorithmic architecture—it is the sheer lack of training data. While large language models can scrape the entire internet for text, robotics companies are forced to rely on expensive, slow, and often ineffective real-world video collection. To bridge this gap, Paris and San Francisco-based startup Physicl has secured $10 million in seed funding led by Inovia Capital to generate high-fidelity synthetic data for robotic training.
Founded by Alex de Vigan, who previously built 3D rendering pipelines for e-commerce retailers, Physicl is repurposing commercial 3D modeling technology to solve robotic edge cases. The company's newly launched Studio platform provides 10,000 environments and 100,000 assets, allowing AI developers to create highly specific training scenarios. Instead of hoping a robot encounters a partially obscured cup in the real world, developers can instantly generate thousands of variations of that exact scenario, adjusting lighting, camera angles, and clutter while maintaining accurate real-world physics.
This approach addresses a critical flaw in existing simulators, which often fail to replicate the complex physics and visual noise of unstructured environments. By providing a scalable way to train models on rare edge cases, Physicl is positioning itself as essential infrastructure for the embodied AI boom. As billions of dollars flow into humanoid hardware and autonomous systems, the race is shifting toward the simulation layers that will actually make these machines reliable enough for commercial deployment.
INTELLIGENCE BRIEF
WHY IT MATTERS
Physical AI lacks a massive, pre-existing dataset like the internet text used for LLMs. Startups that can generate accurate, physics-grounded synthetic data are building the foundational infrastructure needed to bring autonomous robots out of the lab and into unstructured real-world environments.
WHO IS INVOLVED
Physicl founder and CEO Alex de Vigan, Inovia Capital partner Steve Woods, and US Venture Partners.
MARKET IMPACT
As hardware capabilities outpace software reliability in robotics, investment is shifting rapidly toward data generation and simulation layers. Physicl's funding signals growing VC appetite for specialized tooling that solves the 'edge case' deployment blocker for autonomous systems.
This story was drafted with AI assistance and reviewed by TurkSpark editors before publication. Facts, figures, and names may be inaccurate — verify important details independently.
Zipline Secures $1.5B at $21.5B Valuation to Scale Autonomous Drone Delivery Network
Read
HeadOffice.ai Raises New Funding as Enterprise Customers Turn Into Investors
Read